Publications
You can also find my articles on my Google Scholar profile.
2026 | |
| FAITH: Feasibility-Aware Safety-Filtered RL for High-Dimensional Systems arXiv preprint arXiv:2610.12432, 2026. arXiv | |
| LASER: Latent Space Adjoint Matching for Support-Constrained Entropy-Regularized Offline RL Conference on Neural Information Processing Systems (NeurIPS), 2026. Website | 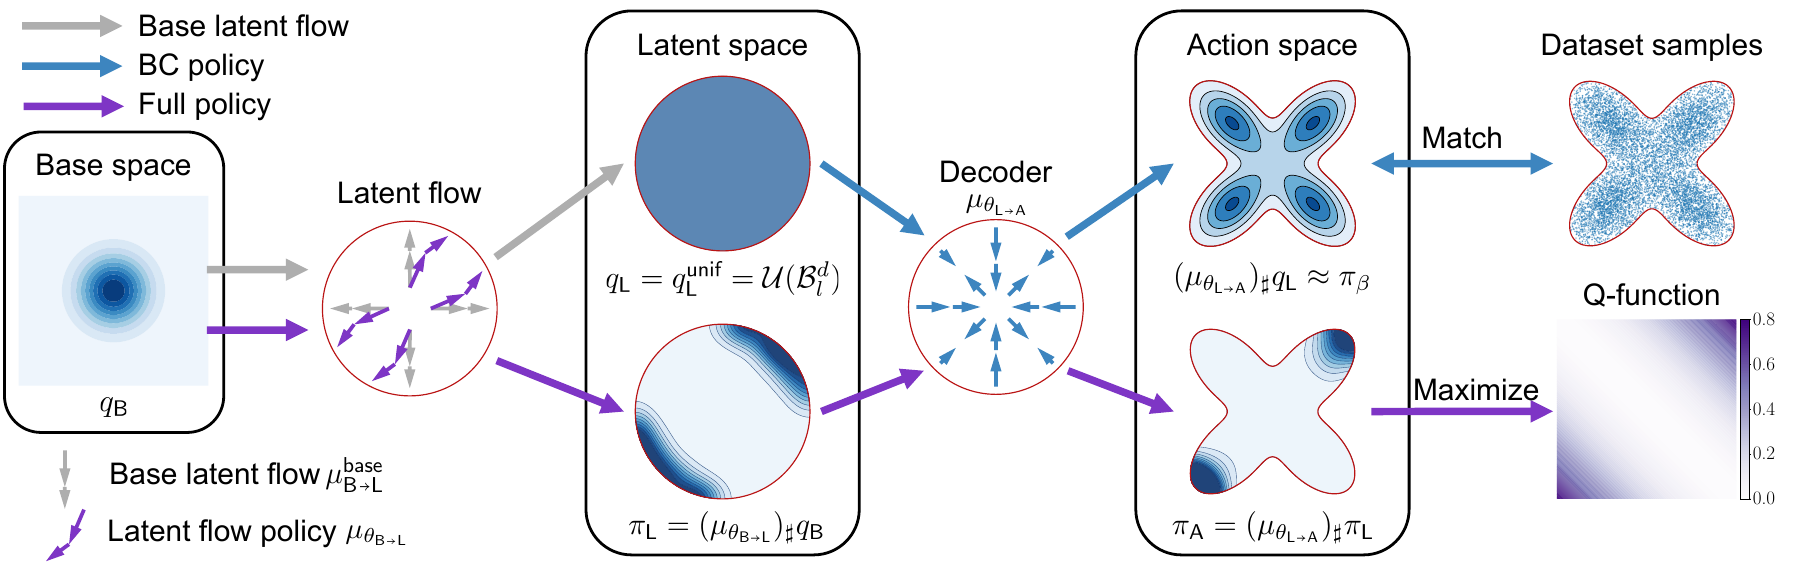 |
| Unified Overview of Safety Certificate Functions: Techniques from Hamilton–Jacobi Reachability and Control Barrier Functions 65th IEEE Conference on Decision and Control (CDC), 2026. arXiv | 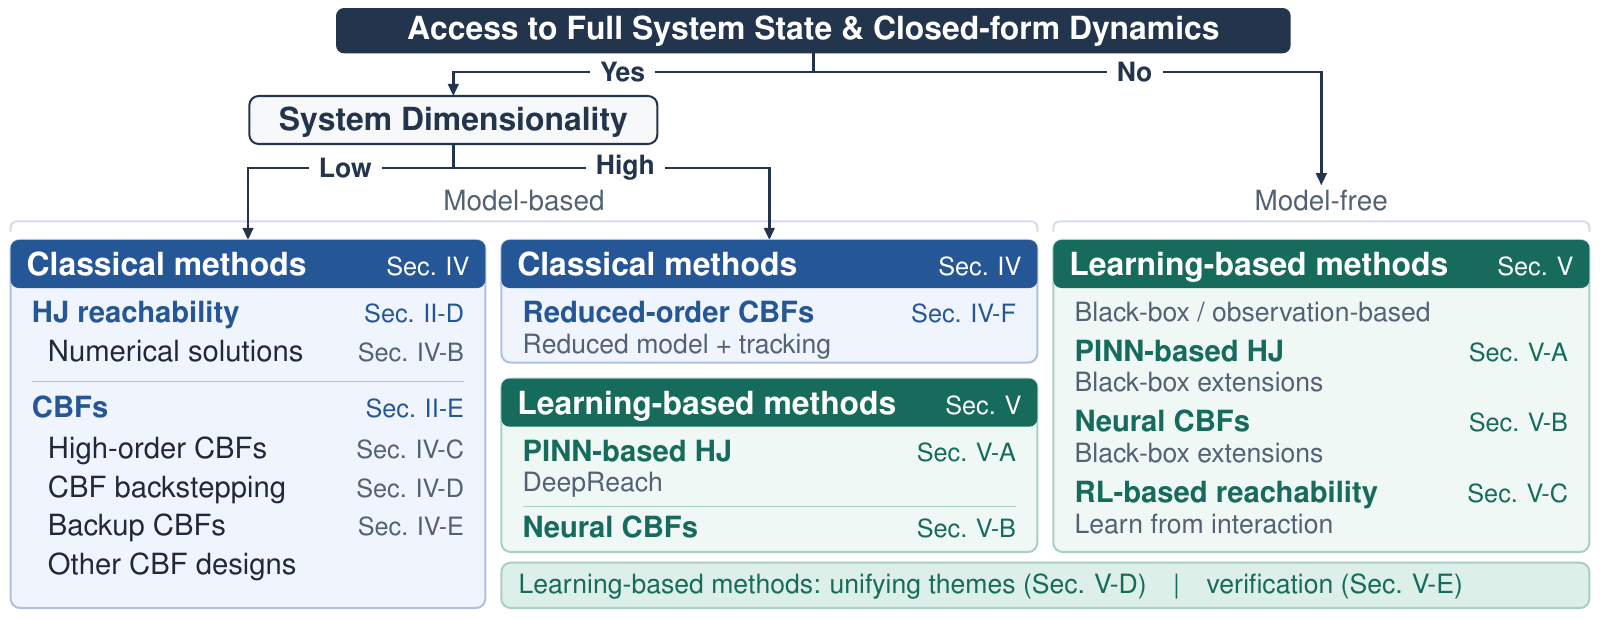 |
| Safe and Scalable Multi-Drone Payload Transport via CBF-based Reinforcement Learning with Zero-Shot Sim-to-Real Transfer IEEE Robotics and Automation Letters (RA-L), 2026. arXiv | 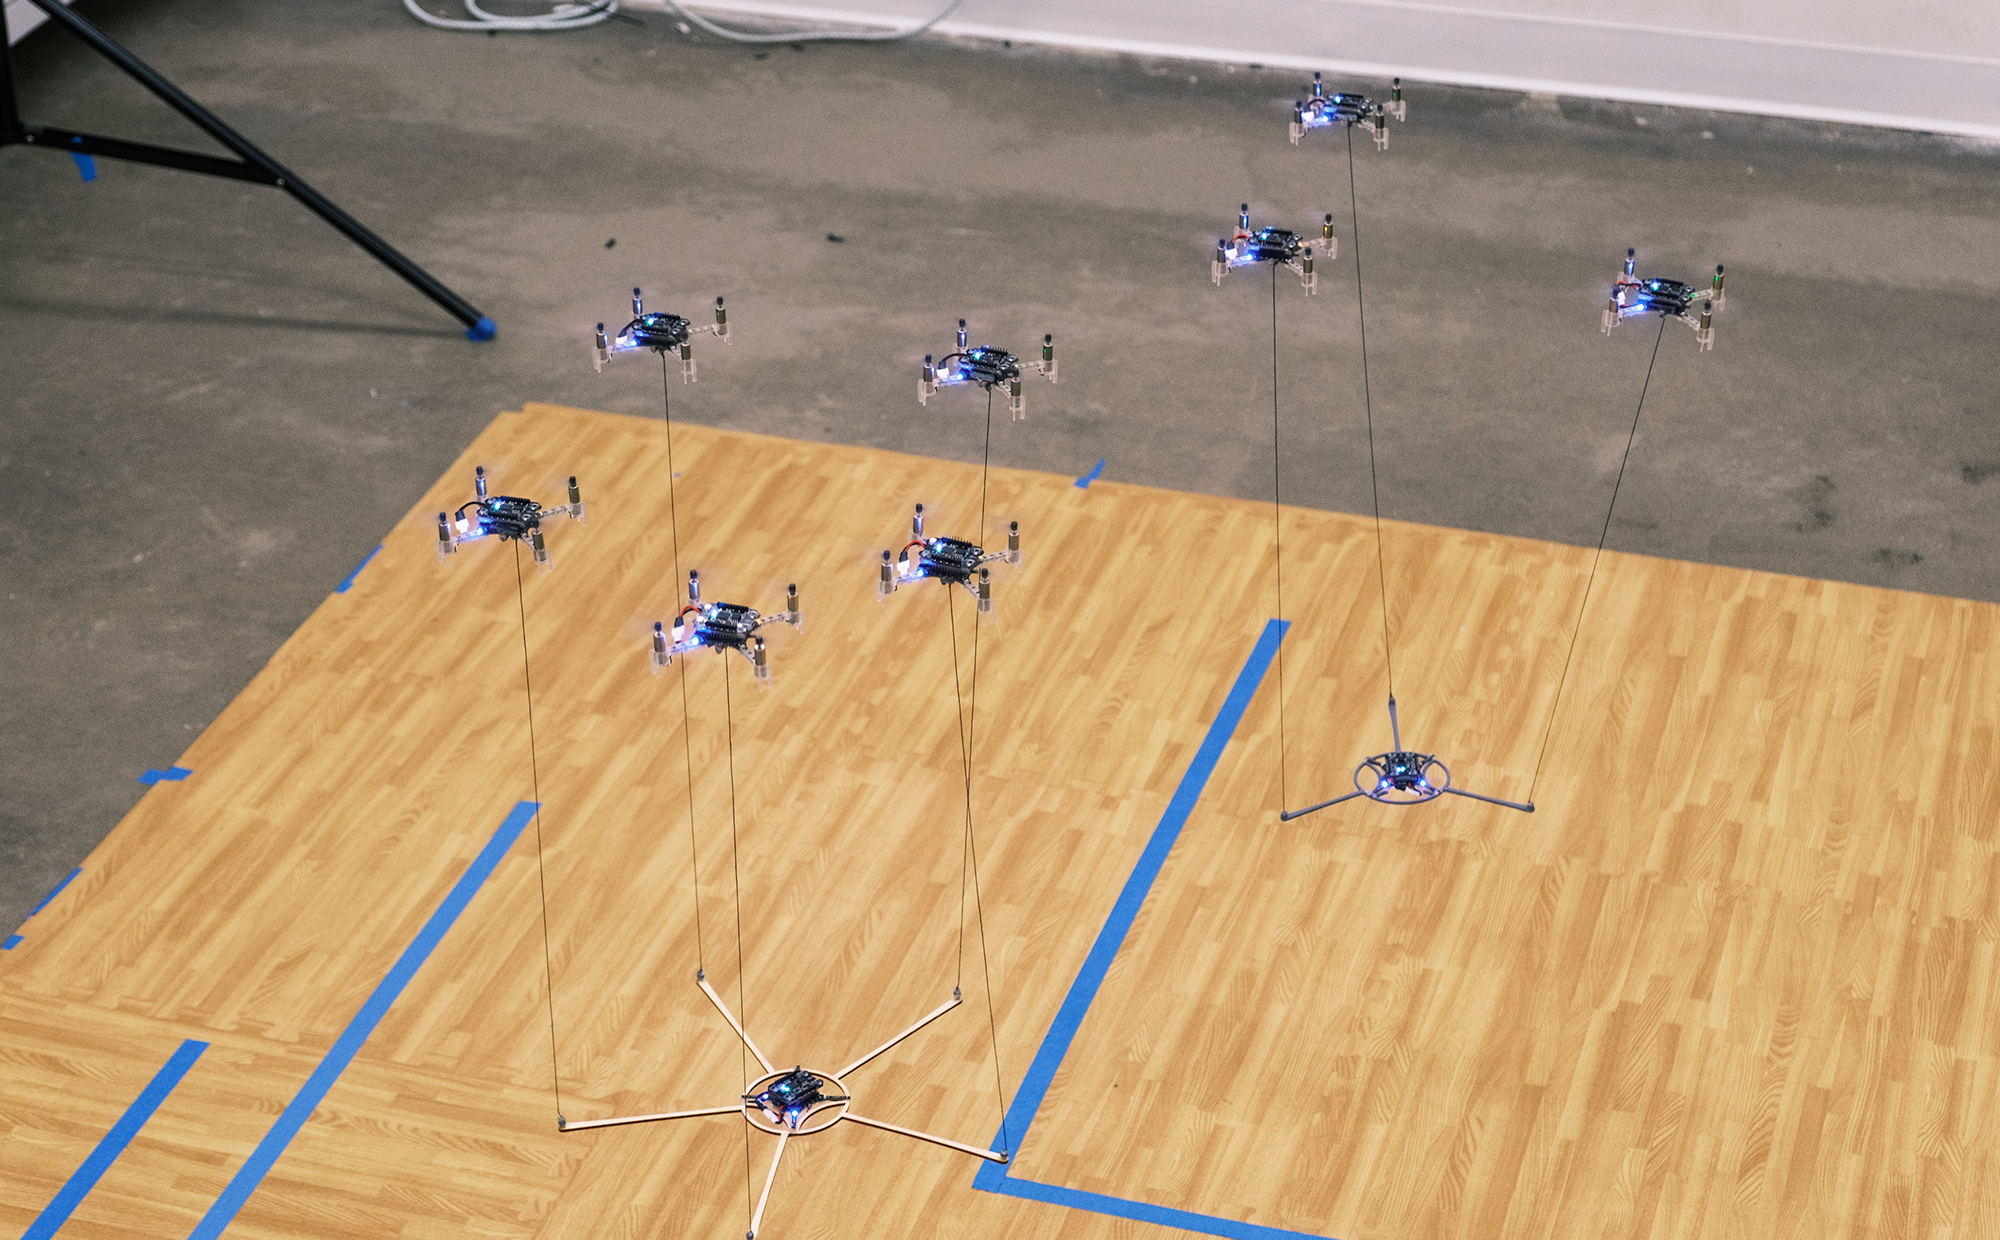 |
| Hamiltonian Grid-Forming: Methodology and Applications for IBR-Rich Grid Operations IEEE Transactions on Industry Applications, 2026. | 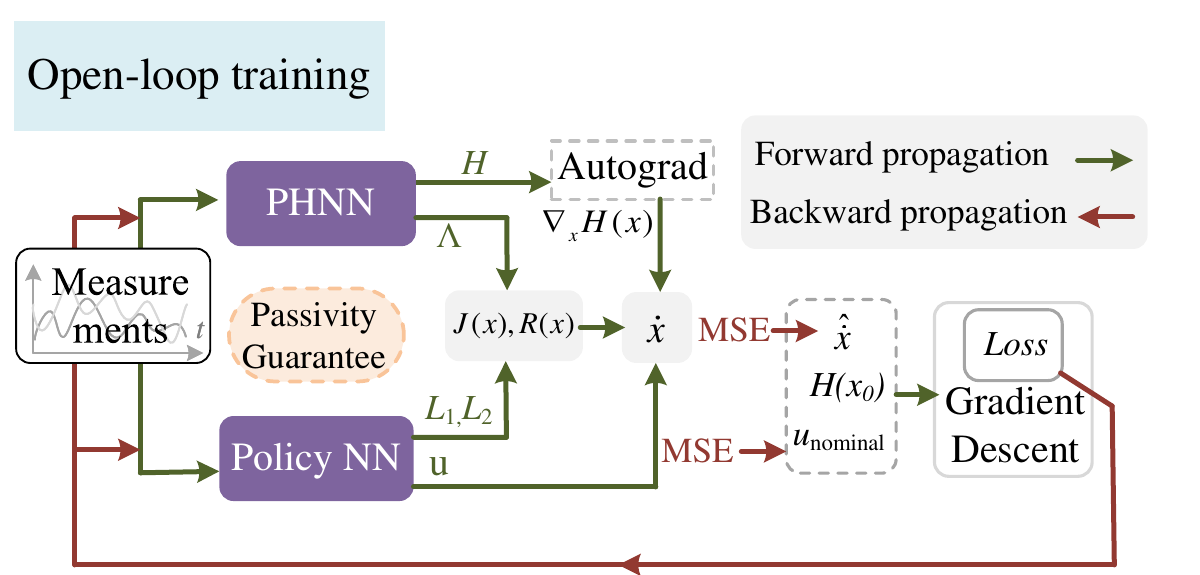 |
| Beyond Waypoints: Semantic-Centric Autonomy with Unreliable Maps Through Learned Abstractions IEEE International Conference on Robotics and Automation (ICRA), 2026. |  |
| ReFORM: Reflected Flows for On-support Offline RL via Noise Manipulation International Conference on Learning Representations (ICLR), 2026. Website |  |
| Solving Parameter-Robust Avoid Problems with Unknown Feasibility using Reinforcement Learning International Conference on Learning Representations (ICLR), 2026. Website |  |
2025 | |
| HMARL-CBF – Hierarchical Multi-Agent Reinforcement Learning with Control Barrier Functions for Safety-Critical Autonomous Systems Conference on Neural Information Processing Systems (NeurIPS), 2025. Website |  |
| Solving Multi-Agent Safe Optimal Control with Distributed Epigraph Form MARL Proceedings of Robotics: Science and Systems (RSS), 2025. [Best Student Paper Award] Website |  |
| Discrete GCBF Proximal Policy Optimization for Multi-agent Safe Optimal Control International Conference on Learning Representations (ICLR), 2025. Website |  |
| GCBF+: A Neural Graph Control Barrier Function Framework for Distributed Safe Multi-Agent Control IEEE Transactions on Robotics, 2025. Website |  |
2024 | |
| Learning to Stabilize High-dimensional Unknown Systems Using Lyapunov-guided Exploration 6th Annual Learning for Dynamics & Control Conference (L4DC), 2024. Website |  |
| Learning Safe Control for Multi-Robot Systems: Methods, Verification, and Open Challenges Annual Reviews in Control (ARC), vol. 57, p. 100948, 2024. arXiv |  |
| Foundation Models to the Rescue: Deadlock Resolution in Connected Multi-Robot Systems arXiv preprint arXiv:2404.06413 arXiv |  |
2023 | |
| Neural Graph Control Barrier Functions Guided Distributed Collision-avoidance Multi-agent Control 7th Conference on Robot Learning (CoRL), 2023. Website |  |
| Physics-Informed, Safety and Stability Certified Neural Control for Uncertain Networked Microgrids IEEE Transactions on Smart Grid, 2023. |  |
| Learning-Based, Safety and Stability-Certified Microgrid Control 2023 IEEE Power & Energy Society General Meeting (PESGM), 2023. |  |
| Compositional Neural Certificates for Networked Dynamical Systems 5th Annual Learning for Dynamics & Control Conference (L4DC), 2023. [Oral] Website |  |
2021 | |
| Confidence-Aware Imitation Learning from Demonstrations with Varying Optimality Conference on Neural Information Processing Systems (NeurIPS), 2021. Website |  |